Take Ohkawa
Hi, I'm a Research Scientist at AIRoA, working on Vision-Language-Action (VLA) systems. I also work as a Cooperative Research Fellow at the Institute of Industrial Science, UTokyo.
I received my PhD from UTokyo in 2025, advised by Prof. Yoichi Sato.
During my PhD journey, I served as Google PhD Fellow in 2024.
I joined Prof. Marc Pollefeys lab at ETH Zurich in 2023, and Prof. Kris Kitani lab at CMU in 2021.
I interned at Meta Reality Labs in Pittsburgh (2024) and Redmond (2022), and collaborated with OMRON SINIC X.
E-mail: tohkawa [dot] contact [at] gmail [dot] com |
|
 AIRoA |
|
|
|
|
|
|
News
[Nov 2026] Released "A-0", our robot foundation model trained on handheld YUBI data, with open-source weights and code! Past updates[Jul 2026] Gave a lecture on “Scaling and Architecture” for Physical AI course, organized by UTokyo Matsuo-Iwasawa Lab.[Jun 2026] Paper "AffHandGen" got accepted to ECCV 2026! [Jun 2026] Paper "YUBI" got accepted to the Beyond Teleop and VLA Pipelines Workshops at ICRA 2026! [Jun 2026] Paper "Physics-aware HOI Generation" got accepted to the PhysHuman Workshop at CVPR 2026 as an Oral! [Mar 2026] Our VLA team will host the ICRA2026 workshop for VLA Pipelines! Excited to see you in Vienna! [Mar 2026] Received Dean's Award & Chair's Awards from UTokyo! [Jan 2026] Received JSPS Ikushi Prize for my PhD study! [Dec 2025] Invited to give a talk at Google Developer Groups AI for Science - Japan! [Nov 2025] Paper "DF-Mamba" got accepted to WACV 2026! [Sep 2025] Five papers "AssemblyHands-X", "AffHandGen", "RGB2Event", "DF-Mamba", "SCGen" got accepted to ICCVW 2025! [Jul 2025] Defended my PhD🧑🎓! [Jun 2025] Paper "SCGen" got accepted to ICCV 2025! [Jun 2025] Received EgoVis Distinguished Paper Award, CVPR 2025! [Apr 2025] 9th HANDS workshop proposal got aceepted to ICCV 2025! See you in Hawaii! [Apr 2025] Invited to give a talk at UIUC Vision Seminar! [Jan 2025] Paper "SiMHand" got accepted to ICLR 2025. [Nov 2024] Received Google PhD Fellowship in Machine Perception! [Oct 2024] Paper "Exo2EgoDVC" got accepted to WACV 2025. [Jul 2024] Three papers "HANDS'23 Analysis", "GHTT", "HandCLR" got accepted to ECCV 2024. [Jun 2024] Started an internship at Meta Reality Labs @Pittsburgh. [Apr 2024] Two papers "S2DHand" and "Exo2EgoDVC" got accepted to CVPR 2024. [Apr 2024] 8th HANDS workshop proposal got aceepted to ECCV 2024 with Dr. Linlin at CUC. See you in Milan! [Apr 2024] Gave an invited presenatation at JST ASPIRE HCVM workshop, UTokyo-IIS. [Jul 2023] Paper "Survey on 3D Hand Pose Estimation" got accepted to IJCV. [Jul 2023] Started working as a Visiting Researcher at CVG Group, ETH Zurich. [Jun 2023] Invited to give a talk at CVML Group, NUS. [Apr 2023] Research proposals got accepted to JST ACT-X Acceleration Phase and MSRA. [Mar 2023] Host 7th HANDS workshop at ICCV 2023 with Prof. Angela at NUS. See you in Paris! [Feb 2023] Paper "AssemblyHands" got accepted to CVPR 2023. [Jul 2022] Paper "Hand State Estimation in the Wild" got accepted to ECCV 2022. [Feb 2022] Received UTokyo-IIS Research Collaboration Initiative Award with Oculus Quests! [Sep 2021] Obtained M.A.S. for 1.5 years (Early Graduation), UTokyo. [Jun 2021] Paper "Domain Adaptation of Hand Segmentation" got accepted to IEEE Access 2021. [Oct 2020] Research proposal got accepted to JST ACT-X. [Oct 2020] Paper "Augmented Cyclic Consistency Regularization" got accepted to ICPR2020. [Apr 2020] Joined Sato/Sugano Lab at UTokyo. [Mar 2020] Obtained B.E. for 3 years (Early Graduation) at TokyoTech. [Oct 2019] Gifted NVIDIA RTX 2080Ti from Yu Darvish, a Japanese MLB player who I respect the most! [Oct 2019] Joined Inoue Lab at TokyoTech. |
ResearchI'm interested in computer vision, machine learning, and robotics for embodied AI, aiming to enable agents that can perceive, understand, and generate interactions in the real world. My research interest includes:
If you're interested in working with me, please visit my contact page and feel free to reach out! |
|
AIRoA-0 (A-0): Long-Horizon, Precise, Cross-Embodiment Manipulation from Handheld Data
Yueh-Hua Wu*†, Kei Ota*, ..., Takehiko Ohkawa, ..., and Zixuan Zhong (*Project Lead, †Research Lead) Technical Report, 2026 [Project] [Paper] [Code] A-0 is a robot foundation model trained on handheld YUBI demonstrations for long-horizon, precise manipulation across embodiments. Weights and code are released as open source. |
|
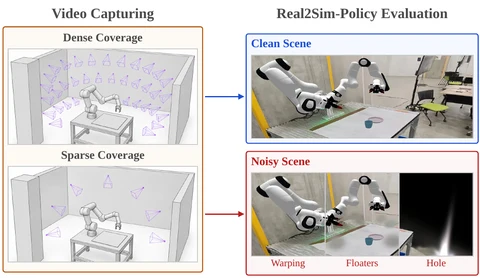
YUBI-Real2Sim: 3DGS Scene Verification for Reliable Policy Evaluation
Hiroki Nishizawa, Takehiko Ohkawa, Nicola Scianca, Tatsuya Matsushima, Shigeo Morishima, and Kei Ota Conference on Robot Learning (CoRL) Late-Breaking Results, Real2Sim2Real Track, 2026 UMI Arena, Conference on Robot Learning Workshops (CoRLW), 2026 [Paper] We present YUBI-Real2Sim, a 3DGS-based real-to-sim framework for evaluating VLA policies under dual fisheye wrist views. It combines 200-degree fisheye capture, 3DGS training, 3D foundation models for objects, and MuJoCo physics, and quantifies the reconstruction quality that reliable policy evaluation requires. |
|
YUBI Go: Portable Robot Data Collection Anywhere with Bimanual Handheld Grippers
Yuki Noguchi, Yuya Kanai, Kengo Ikeuchi, Makoto Sugiura, Takuya Okubo, Petr Khrapchenkov, Tatsuya Matsushima, Kei Ota*, and Takehiko Ohkawa* (*equal advising) UMI Arena Device Track, Conference on Robot Learning Workshops (CoRLW), 2026 [Code] YUBI Go is an open-source Quest app for collecting YUBI robot data anywhere. |
|
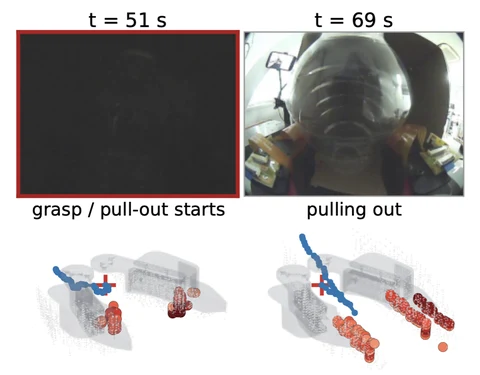
YUBI in the Dark: Tactile Sensing from Hand-Held Grippers Guides Manipulation under Limited Vision
Yuma Shin, Takehiko Ohkawa, Makoto Sugiura, Takuya Okubo, Asako Kanezaki, Kei Ota, and Rei Kawakami UMI Arena Paper Track, Conference on Robot Learning Workshops (CoRLW), 2026 We equip YUBI, a finger-driven hand-held gripper, with FlexiTac tactile sensors to collect synchronized visual-tactile demonstrations, and show that touch guides manipulation when vision is limited. |
|
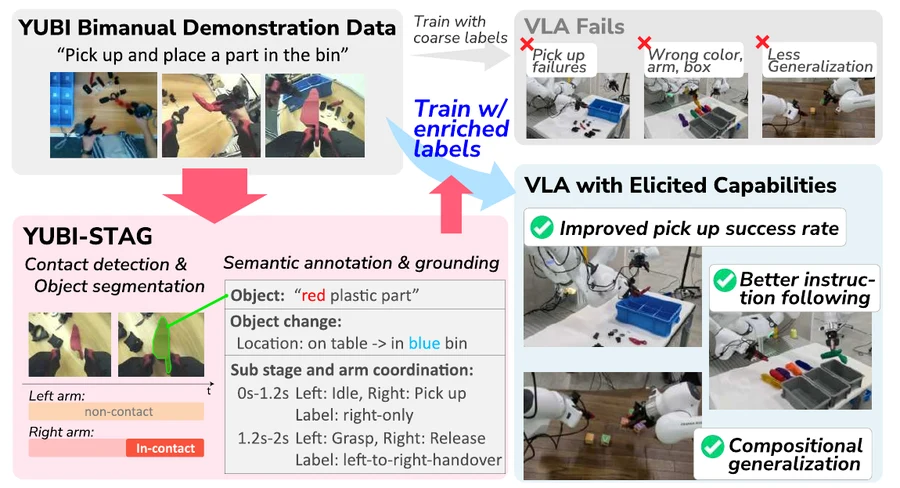
YUBI-STAG: Contact and Semantic-Rich Alignment for VLAs via Automated Video-Language Grounding
Masatoshi Tateno†, Takehiko Ohkawa‡, Yueh-Hua Wu, Hanlong Li, Tatsuya Matsushima, Yoichi Sato, and Kei Ota (†VLM Lead, ‡VLA Lead) UMI Arena Paper Track, Conference on Robot Learning Workshops (CoRLW), 2026 (Spotlight) [Project] [Paper] We introduce YUBI-STAG, a spatio-temporal annotation and grounding framework that automatically enriches manipulation demonstrations with interaction-rich language. Combining contact-object segmentation with vision-language models, it annotates object attributes and states, per-gripper actions, and bimanual coordination to align pretrained VLAs with fine-grained instructions. |
|
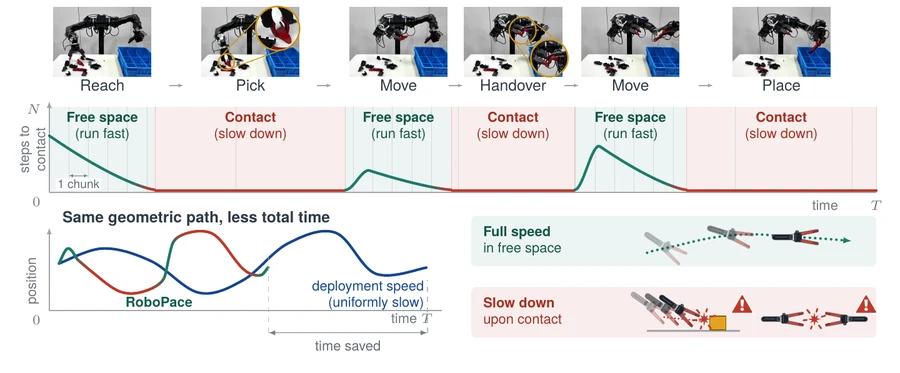
RoboPace: Contact-Aware Time-Optimal Retiming for Action-Chunk Policies
Mimo Shirasaka, Takehiko Ohkawa, Takuya Okubo, Nicola Scianca, Tatsuya Matsushima, and Kei Ota UMI Arena, Conference on Robot Learning Workshops (CoRLW), 2026 [Project] [Paper] We present RoboPace, an online retiming layer for action-chunk policies that keeps the policy's geometric path while adapting its timing to the target robot. It slows down around predicted contact and speeds up in free space within the robot's kinematic and dynamic limits. |
|
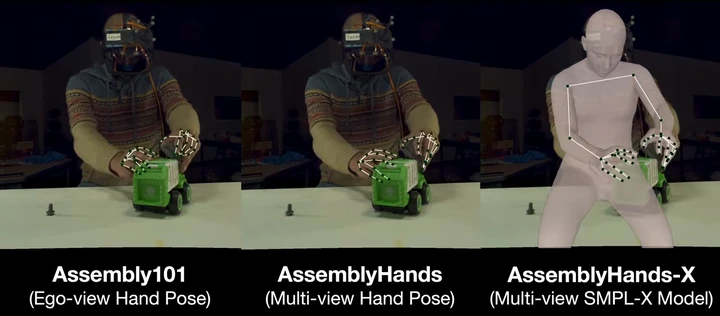
AssemblyHands-X: Modeling Hand, Body, and Visual Context for Understanding Bimanual Human Activities
Tatsuro Banno, Takehiko Ohkawa, Naru Suzuki, Ruicong Liu, Taein Kwon, Kun He, Risa Shinoda, Ryosuke Furuta, and Yoichi Sato IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2027 HANDS, International Conference on Computer Vision Workshops (ICCVW), 2025 [Project] [Paper] We present AssemblyHands-X, the first markerless 3D hand-body benchmark for understanding bimanual human activities. We reconstruct temporally consistent SMPL-X hand-body motion for 2.8M images from the multi-view videos of Assembly101, and show that modeling hand, body, and visual cues jointly improves action recognition. |
|
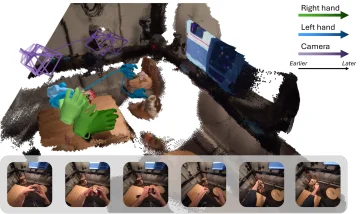
DewHand: Direct Metric World-Space Hand Motion Reconstruction from Egocentric Videos
Naru Suzuki, Satoshi Ikehata, Takehiko Ohkawa, Yoichi Sato, and Shuhei Kurita Preprint, 2026 [Project] [Paper] We present DewHand, a single-stage model that jointly reconstructs hand and camera motion in a shared metric world frame from egocentric video. It combines scene-level geometric features with metric-space supervision to resolve scale ambiguity, while hand-specific features preserve fine articulation. |

|
YUBI: Yielding Universal Bidigital Interface for Bimanual Dexterous Manipulation at Scale
Takehiko Ohkawa*, Jumpei Arima*, Yuki Noguchi, Masatoshi Tateno, ..., and Kei Ota (*project co-lead) Conference on Robot Learning (CoRL), 2026 (Demo) Beyond Teleoperation and VLA Pipelines, International Conference on Robotics and Automation Workshops (ICRAW), 2026 [Project] [Paper] [Code] [Hardware] We introduce YUBI, a finger-aligned gripper for intuitive, ergonomic, and scalable data collection in bimanual dexterous manipulation. With integrated VR-based 6 DoF tracking, YUBI enables a UMI-based dataset of unprecedented scale (8434 hours, 1.20M episodes, 119 tasks), and a single policy trained on it transfers across multiple bimanual robots (UR, Franka, and ELEY). |
|
The UMI Arena: From Handheld Devices to Real-World Policies
Contributed as an organizer Conference on Robot Learning Workshops (CoRLW), 2026 [Workshop] [Call for Papers] The UMI Arena builds a shared environment for evaluating UMI-style manipulation. It pairs a 15,000-hour release of handheld demonstration data with a live policy competition run by the organizers on common robots, so entries are compared on the same tasks under the same conditions. The program also features a hands-on device exhibition and contributed papers. |

|
SiMDex: Mining Similar Egocentric Videos for Cross-Embodiment Dexterous Manipulation
Nie Lin, Takehiko Ohkawa, Sijin Chen, Ruoshi Wen, Zhuohang Li, Liqun Huang, Zhengming Zhu, Yiming Bao, Yunfei Li, Minjie Cai, Xiao Ma, Wei Xu, and Yoichi Sato Preprint, 2026 [Project] [Paper] [Video] We cast human video selection for robot learning as a recommendation problem, mining task-relevant clips from large-scale egocentric data by language and hand-pose retrieval, action-chunk ranking, and optical-flow verification. Training on under 5% of the pool raises the success rate of dexterous manipulation from 47.7% to 61.1%, showing that selective curation beats indiscriminate data mixing. |

|
EgoYUBIs: Portable Robot Data Collection with Bimanual Handheld Grippers via Egocentric Perception
Takehiko Ohkawa, Masatoshi Tateno*, Kengo Ikeuchi*, Kei Ota, and Yoichi Sato (*equal contribution) Meta Research Summit for Egocentric Intelligence, 2026, Oral and Poster Presentation (Best Poster Award) [Poster] [Video] EgoYUBIs combines YUBI with egocentric perception for portable, wearable data collection in bimanual dexterous manipulation. The Aria-based setup integrates marker-cube tracking, wrist-camera SLAM, and interaction perception for in-the-wild robot data collection. |

|
Affordance-Guided Diffusion Prior for 3D Hand Reconstruction
Naru Suzuki*, Takehiko Ohkawa*, Tatsuro Banno, Jihyun Lee, Ryosuke Furuta, and Yoichi Sato (*equal contribution) European Conference on Computer Vision (ECCV), 2026 HANDS, International Conference on Computer Vision Workshops (ICCVW), 2025 Oral Presentation at Meeting on Image Recognition and Understanding (MIRU), 2026 (MIRU Excellent Student Award) [Project] [Paper] [Code] We propose a generative prior for hand pose refinement guided by affordance-aware textual descriptions of hand-object interactions. Our method employs a diffusion-based generative model that learns the distribution of plausible hand poses conditioned on affordance descriptions, which are inferred from VLMs. |

|
Physically Plausible Human-Object Interaction Generation via Attribute Classifier Guidance
Kengo Ikeuchi, Takehiko Ohkawa, Risa Shinoda, and Yoichi Sato PhysHuman, IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops (CVPRW), 2026 (Oral) [Paper] We propose Attribute Classifier Guidance, a plug-and-play framework that adapts large pre-trained motion diffusion models for physical-attribute-aware human-object interaction synthesis. It steers the diffusion sampling process with the gradients of a lightweight attribute classifier, improving physical realism (e.g., mass-aware posture) while maintaining competitive generation quality. |
|
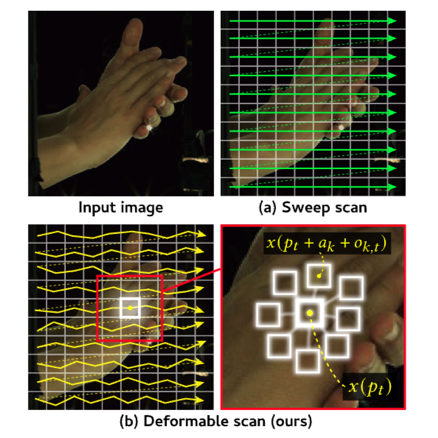
DF-Mamba: Deformable State Space Modeling for 3D Hand Pose Estimation in Interactions
Yifan Zhou*, Takehiko Ohkawa*, Guwenxiao Zhou, Kanoko Goto, Takumi Hirose, Yusuke Sekikawa, and Nakamasa Inoue (*equal contribution) IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2026 HANDS, International Conference on Computer Vision Workshops (ICCVW), 2025 [Project] [Paper] We propose a novel and powerful framework for visual feature extraction in 3D hand pose estimation using recent state space modeling (i.e., Mamba), dubbed Deformable Mamba (DF-Mamba). DF-Mamba is designed to capture global context cues via Mamba's nature of selective state modeling and deformable state scanning. |
|
Leveraging RGB Images for Pre-Training of Event-Based Hand Pose Estimation
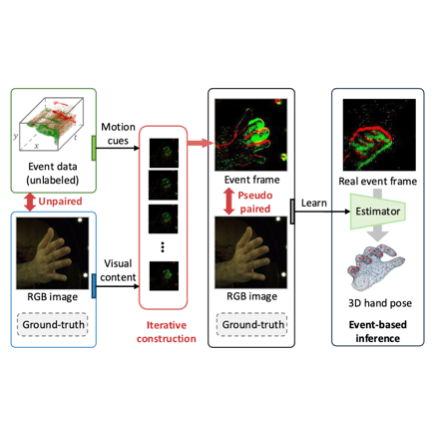
Ruicong Liu, Takehiko Ohkawa, Tze Ho Elden Tse, Mingfang Zhang, Angela Yao, and Yoichi Sato International Conference on Pattern Recognition (ICPR), 2026 HANDS, International Conference on Computer Vision Workshops (ICCVW), 2025 [Paper] This paper presents RPEP, the first pre-training method for event-based 3D hand pose estimation using labeled RGB images and unpaired, unlabeled event data. |

|
Generative Modeling of Shape-Dependent Self-Contact Human Poses
Takehiko Ohkawa, Jihyun Lee, Shunsuke Saito, Jason Saragih, Fabian Prado, Yichen Xu, Shoou-I Yu, Ryosuke Furuta, Yoichi Sato, and Takaaki Shiratori International Conference on Computer Vision (ICCV), 2025 I-HFM & HANDS, International Conference on Computer Vision Workshops (ICCVW), 2025 [Project] [Paper] [Poster] We introduce the first extensive self-contact dataset with precise body shape registration, Goliath-SC, consisting of 383K self-contact poses across 130 subjects. Using this dataset, we propose generative modeling of a self-contact prior conditioned by body shape parameters, based on a body-part-wise latent diffusion with self-attention. |

|
Visual Understanding of Human Hands in Interactions
Takehiko Ohkawa Doctoral Dissertation, 2025 Ikushi Prize, 2026 Dean's & Chair's Awards, UTokyo, 2026 [Overview] [Paper] [Slides] |

|
HANDS Workshops: Observing and Understanding Hands in Action
Contributed as an organizer and challenge committee International Conference on Computer Vision Workshops (ICCVW), 2025 Past editions: [ECCV2024] / [ICCV2023] DetailsHosted challenges:AssemblyHands-S2D@ECCV2024: Dual-view hand pose AssemblyHands@ICCV2023: Single-view hand pose Our HANDS workshop will gather vision researchers working on perceiving hands performing actions, including 2D & 3D hand detection, segmentation, pose/shape estimation, tracking, etc. We will also cover related applications including gesture recognition, hand-object manipulation analysis, hand activity understanding, and interactive interfaces. |

|
EmoSign: A Multimodal Dataset for Understanding Emotions in American Sign Language
Phoebe Chua*, Cathy Mengying Fang*, Takehiko Ohkawa, Raja Kushalnagar, Suranga Nanayakkara, and Pattie Maes (*equal contribution) Preprint [Project] [Paper] We introduce EmoSign, the first sign video dataset containing sentiment and emotion labels for 200 American Sign Language (ASL) videos with open-ended descriptions of emotion cues. Alongside the annotations, we include baseline models for sentiment and emotion classification. |

|
SiMHand: Mining Similar Hands for Large-Scale 3D Hand Pose Pre-training
Nie Lin*, Takehiko Ohkawa*, Yifei Huang, Mingfang Zhang, Minjie Cai, Ming Li, Ryosuke Furuta, and Yoichi Sato (*equal contribution) International Conference on Learning Representations (ICLR), 2025 HANDS, European Conference on Computer Vision Workshops (ECCVW), 2024 Invited Oral Presentation at Meeting on Image Recognition and Understanding (MIRU), 2025 [Project] [Paper] [Code] [Poster] We present a framework for pre-training of 3D hand pose estimation from in-the-wild hand images sharing with similar hand characteristics, dubbed SiMHand. |

|
Exo2EgoDVC: Dense Video Captioning of Egocentric Human Activities Using Web Instructional Videos
Takehiko Ohkawa, Takuma Yagi, Taichi Nishimura, Ryosuke Furuta, Atsushi Hashimoto, Yoshitaka Ushiku, and Yoichi Sato IEEE/CVF Winter Conference on Applications of Computer Vision (WACV), 2025 LPVL, IEEE/CVF Conference on Computer Vision and Pattern Recognition Workshops (CVPRW), 2024 [Project] [Paper] [Data & Code] [Video] We present EgoYC2, a novel benchmark for cross-view knowledge transfer of dense video captioning, adapting models from web instructional videos with exocentric views to an egocentric view. |

|
Benchmarks and Challenges in Pose Estimation for Egocentric Hand Interactions with Objects
Zicong Fan*, Takehiko Ohkawa*, Linlin Yang*, Nie Lin, ..., and Angela Yao (*equal contribution) European Conference on Computer Vision (ECCV), 2024 [Paper] [Poster] We present a comprehensive summary of the HANDS23 challenge using the AssemblyHands and ARCTIC datasets. Based on the results of the top submitted methods and more recent baselines on the leaderboards, we perform a thorough analysis on 3D hand(-object) reconstruction tasks. |

|
Generative Hierarchical Temporal Transformer for Hand Pose and Action Modeling
Yilin Wen, Hao Pan, Takehiko Ohkawa, Lei Yang, Jia Pan, Yoichi Sato, Taku Komura, and Wenping Wang HANDS, European Conference on Computer Vision Workshops (ECCVW), 2024 [Paper] We present a novel framework that concurrently tackles hand action recognition and 3D future hand motion prediction. |

|
Single-to-Dual-View Adaptation for Egocentric 3D Hand Pose Estimation
Ruicong Liu, Takehiko Ohkawa, Mingfang Zhang, Yoichi Sato IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2024 Invited Poster Presentation at EgoVis Workshop, CVPRW, 2024 Invited Oral Presentation at Forum on Information Technology (FIT), 2024 [Paper] [Code] We propose a novel Single-to-Dual-view adaptation (S2DHand) solution that adapts a pre-trained single-view estimator to dual views. |

|
AssemblyHands: Towards Egocentric Activity Understanding via 3D Hand Pose Estimation
Takehiko Ohkawa, Kun He, Fadime Sener, Tomas Hodan, Luan Tran, and Cem Keskin IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR), 2023 EgoVis Distinguished Paper Award, CVPR, 2025 Invited Oral Presentation at Ego4D & EPIC Workshop, CVPRW, 2023 Poster Presentation at International Computer Vision Summer School (ICVSS), 2023 HANDS Workshop Benchmark Dataset, ICCVW, 2023 [Paper] [Project] [Code & Data] We present AssemblyHands, a large-scale benchmark dataset with accurate 3D hand pose annotations, to facilitate the study of challenging hand-object interactions from egocentric videos. |

|
Efficient Annotation and Learning for 3D Hand Pose Estimation: A Survey
Takehiko Ohkawa, Ryosuke Furuta, and Yoichi Sato International Journal of Computer Vision (IJCV), 2023 [Paper] [Springer] [Slides] We present a systematic review of 3D hand pose estimation from the perspective of efficient annotation and learning. 3D hand pose estimation has been an important research area owing to its potential to enable various applications, such as video understanding, AR/VR, and robotics. |

|
Domain Adaptive Hand Keypoint and Pixel Localization in the Wild
Takehiko Ohkawa, Yu-Jhe Li, Qichen Fu, Ryosuke Furuta, Kris M. Kitani, and Yoichi Sato European Conference on Computer Vision (ECCV), 2022 Invited Poster Presentation at HANDS and HBHA workshops, ECCVW, 2022 Invited Oral Presentation at Meeting on Image Recognition and Understanding (MIRU), 2023 [Paper] [Project] [Slides] We tackled domain adaptation of hand keypoint regression and hand segmentation to in-the-wild egocentric videos with new imaging conditions (e.g., Ego4D). |

|
Background Mixup Data Augmentation for Hand and Object-in-Contact Detection
Koya Tango, Takehiko Ohkawa, Ryosuke Furuta, and Yoichi Sato HANDS, European Conference on Computer Vision Workshops (ECCVW), 2022 [Paper] We propose Background Mixup augmentation that leverages data-mixing regularization for hand-object detection while avoiding unintended effect produced by naive Mixup. |

|
Foreground-Aware Stylization and Consensus Pseudo-Labeling for Domain Adaptation of First-Person Hand Segmentation Takehiko Ohkawa, Takuma Yagi, Atsushi Hashimoto, Yoshitaka Ushiku, and Yoichi Sato IEEE Access, 2021 [Paper] [IEEE Xplore] [Project] [Code & Data] We developed a domain adaptation method for hand segmentation, consisting of appearance gap reduction by stylization and learning with pseudo-labels generated by network consensus. |

|
Augmented Cyclic Consistency Regularization for Unpaired Image-to-Image Translation
Takehiko Ohkawa, Naoto Inoue, Hirokatsu Kataoka, and Nakamasa Inoue International Conference on Pattern Recognition (ICPR), 2020 [Paper] We developed extended consistency regularization for stabilizing the training of image translation models using real, fake, and reconstructed samples. |
Honors & Awards
MIRU Excellent Student Award, 2026 |
Grants
ACT-X Travel Grant for International Research Meetings, 2024 |
Talks
Meta Research Summit for Egocentric Intelligence, "EgoYUBIs", Jul 2026. |
Academic ActivitiesProfessional Service:
Organization:
Conference Travel History:
|
|
© Takehiko Ohkawa / Design: jonbarron |